The hidden foundation of safe AI: why execution-layer trust determines real-world safety
Thursday, 26 November 2026 · Software tracks – time and room to be announced
Speaker
About this session
Everyone is talking about AI safety. But what if the biggest safety risk isn’t the AI?
As robotic systems leave controlled factory cells and enter the real world, every autonomous decision ultimately becomes executable C/C++ code running on embedded processors. This execution layer translates AI intent into physical action and determines how a robot behaves.
Although generally less algorithmically complex than the AI stack above it, the execution layer is often the most safety-critical. Compiler and runtime library defects can introduce latent, systematic faults that are rarely exposed through application testing alone, making trust in the execution layer a matter of objective evidence rather than assumption. Safety can’t be built on assumptions; it must be built on evidence.
This talk reveals why trustworthy toolchains are a foundation of safe AI, using real examples of compiler and library defects that silently alter system behavior. We show how software-defined products, OTA updates, open-source adoption and emerging regulations are driving the need for objective, continuous qualification evidence throughout the software lifecycle. Finally, we present an architecture that combines continuous toolchain qualification with a monitored safety envelope, enabling autonomous systems to evolve without compromising safety.
The future of safe AI depends on trustworthy execution.
About the speaker
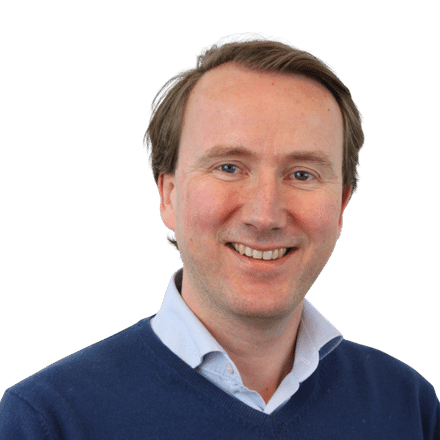
Sjoerd van der Zwaan
Sjoerd van der Zwaan is chief product officer at Solid Sands, supporting the industry with compiler and library qualification for safety-critical systems. With more than thirty years of experience in robotics and autonomous systems, he focuses on building trust in the toolchains that underpin modern AI-enabled products. Previously, as CTO at 2Getthere, he led the development and deployment of autonomous transit systems. His expertise spans the full robotics stack, from perception and control to functional safety and toolchain qualification, helping bridge the gap between rapid AI innovation and evidence-based safety assurance.